Case histories › Case history
Case history
Robotic navigation with the CEE-PILOT™ for precise USV lagoon surveys
A CEE-USV™ with the CEE-PILOT™ followed a 6 m (20 ft) line plan across a coastal lagoon with typical cross track error under 15 cm (6 in), and a maximum drift of only 1.4 m (4.5 ft) in a tidal current. The result is consistent coverage and clean bathymetry in Hydromagic.
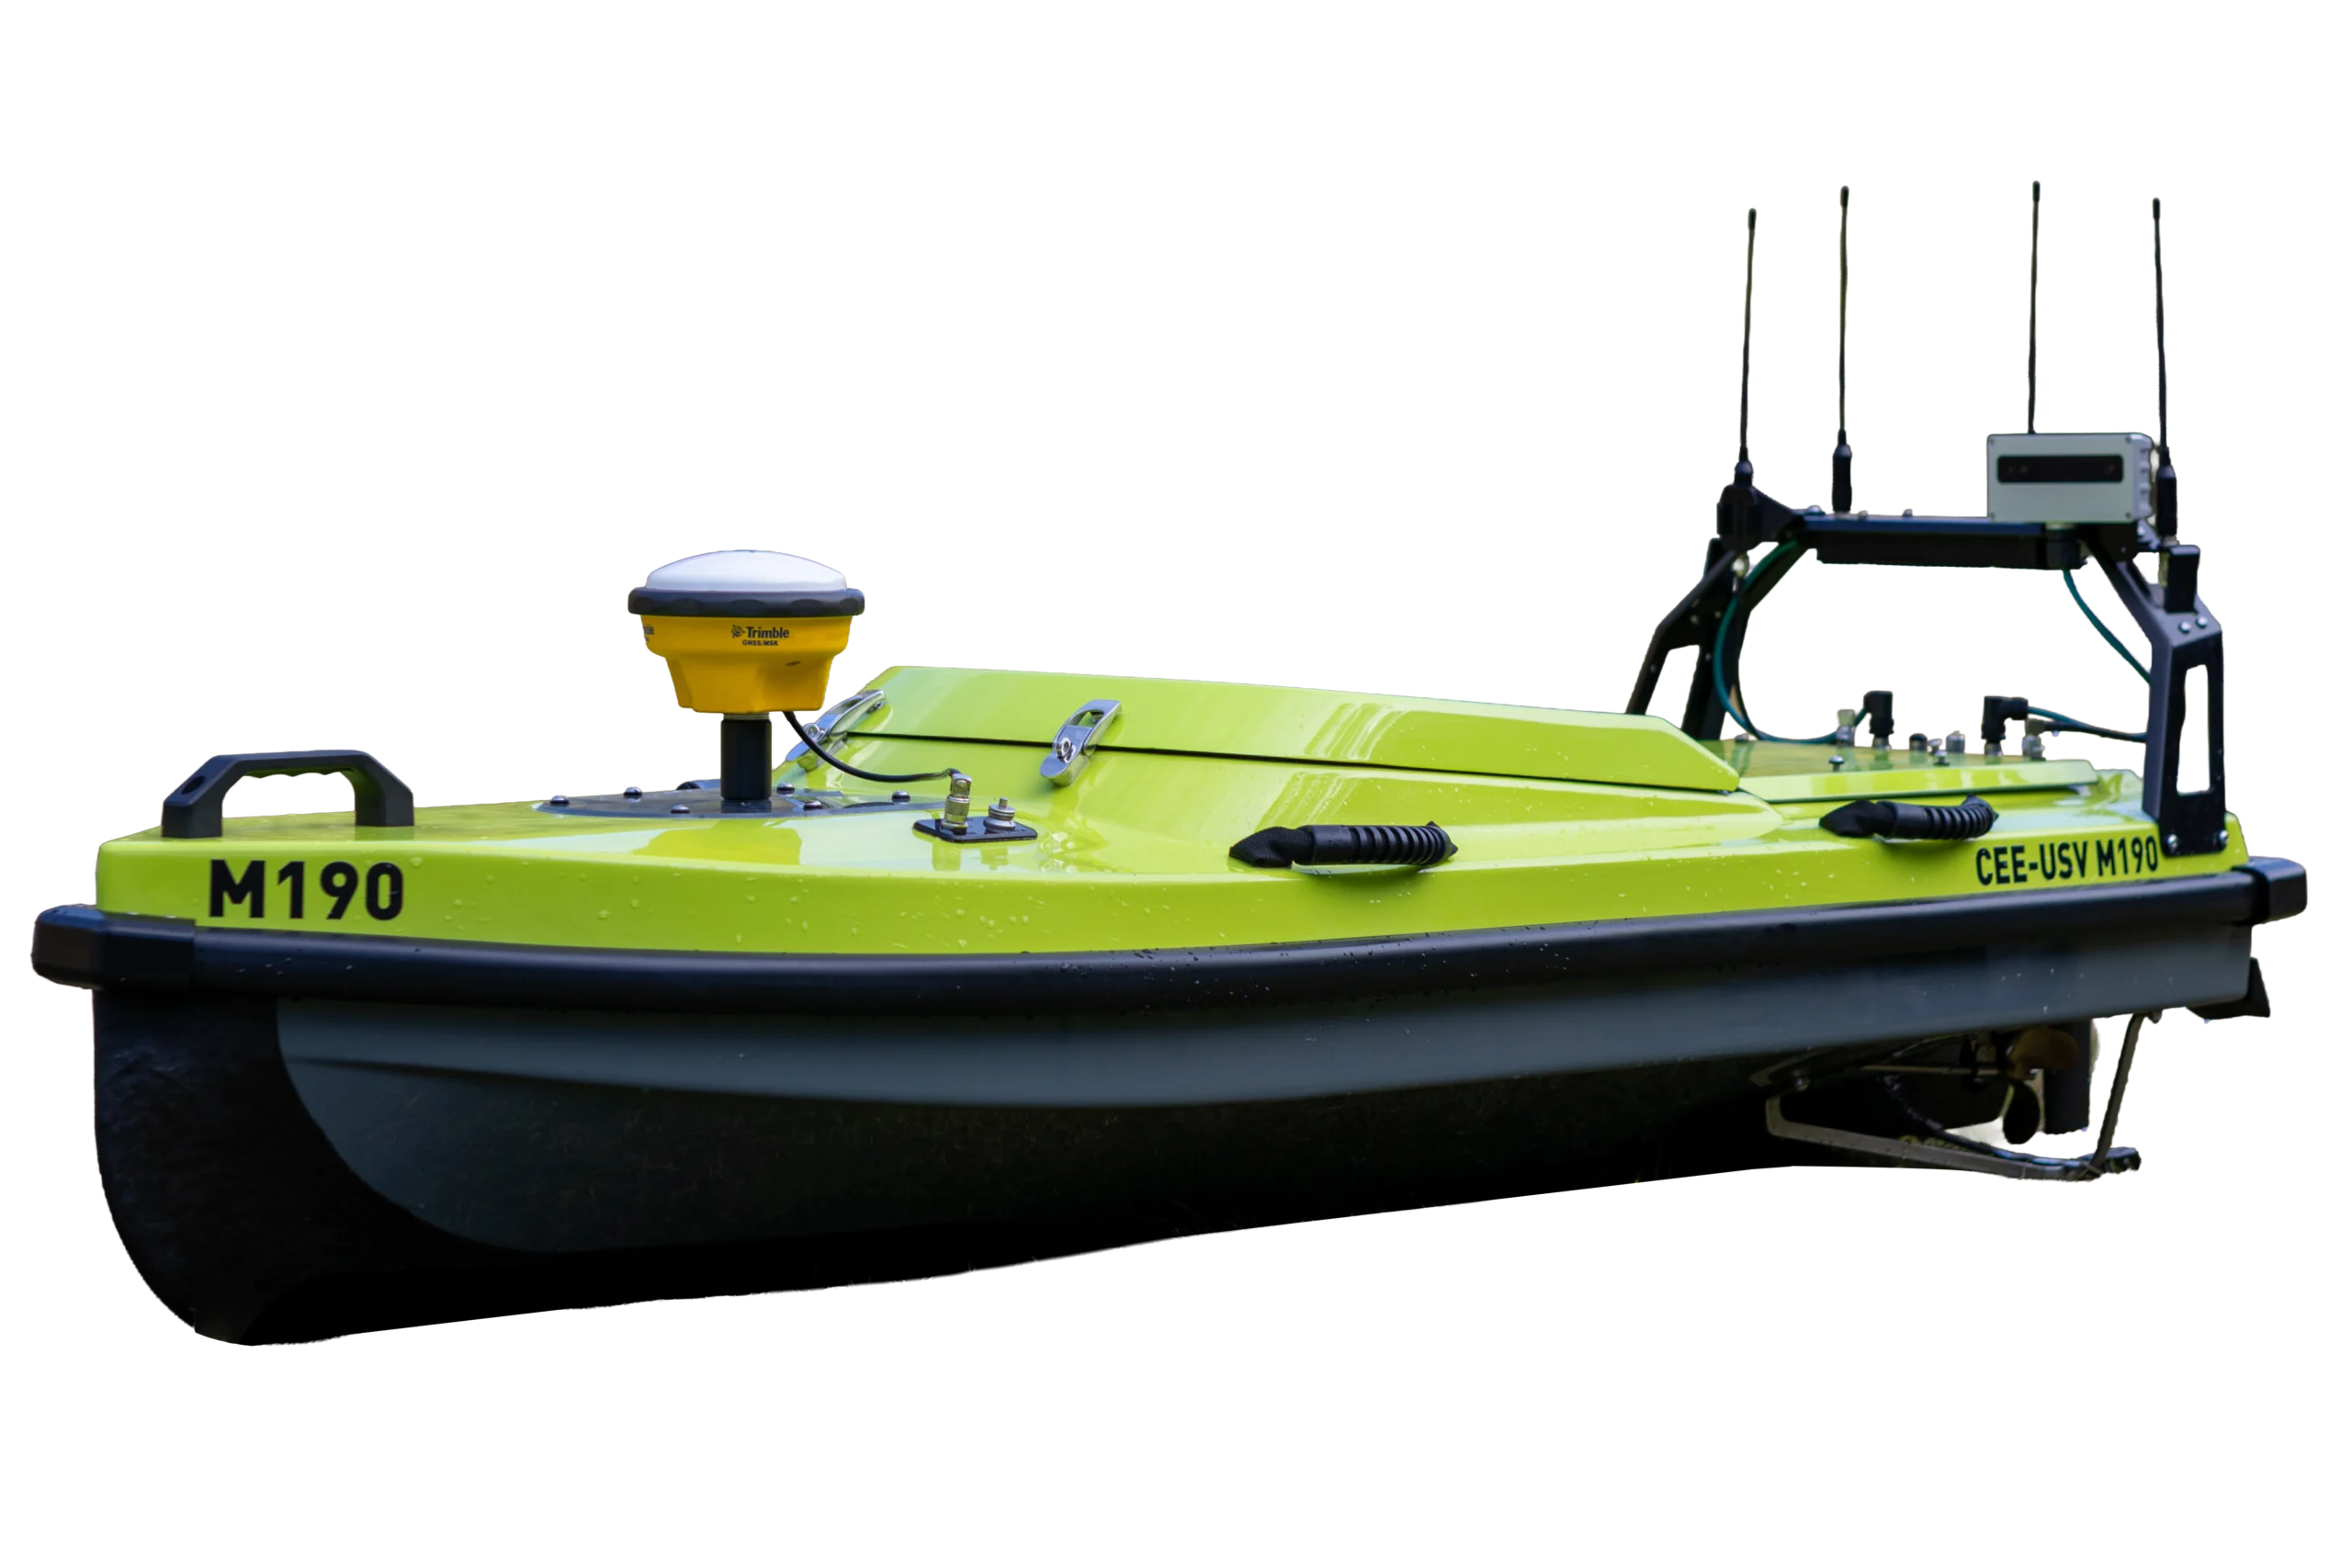
At a glance
- Location
- Coastal lagoon, approx. 300 x 250 m (1000 x 800 ft)
- Application
- Unmanned single beam hydrographic survey with robotic line following
- Equipment
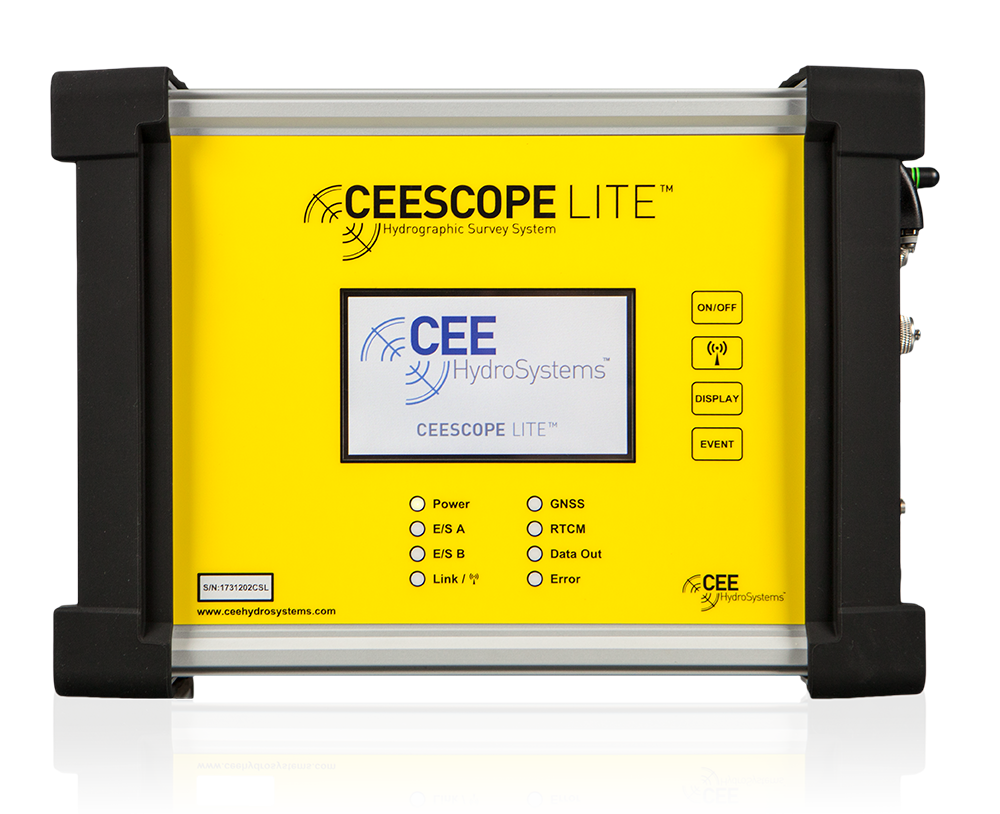
- CEE-USV™ with CEE-PILOT™ robotic navigation controller (Dynautics Ltd SPECTRE™ autopilot) and CEESCOPE™ echo sounder
- Software
- Eye4Software Hydromagic
- Line spacing
- 6 m (20 ft)
- Cross track error
- Typically under 15 cm (6 in) on line
The CEE-USV™ offers a simplified approach to unmanned single beam hydrographic surveying. The challenge for the addition of automation is avoiding complexity and worsening the usability of the system. The CEE-PILOT™ meets this challenge while at the same time presenting the opportunity for exceptional results.
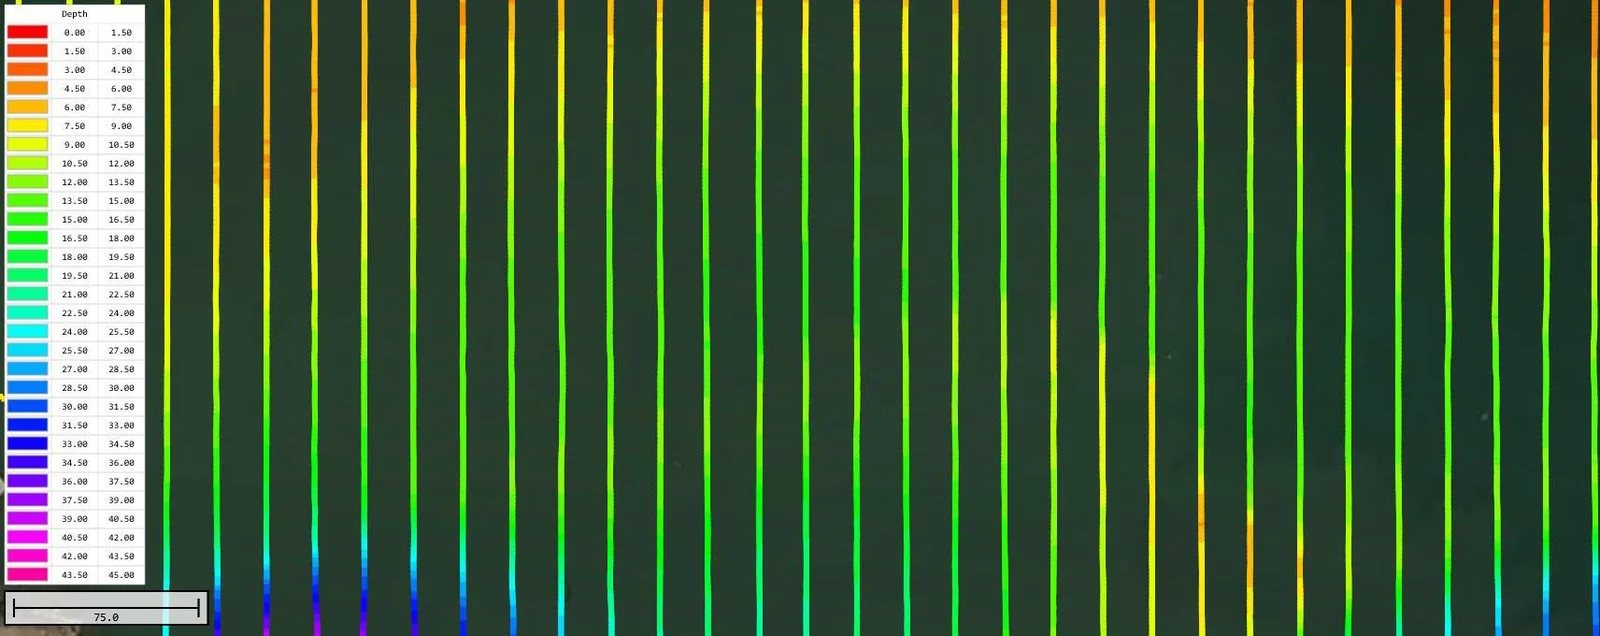
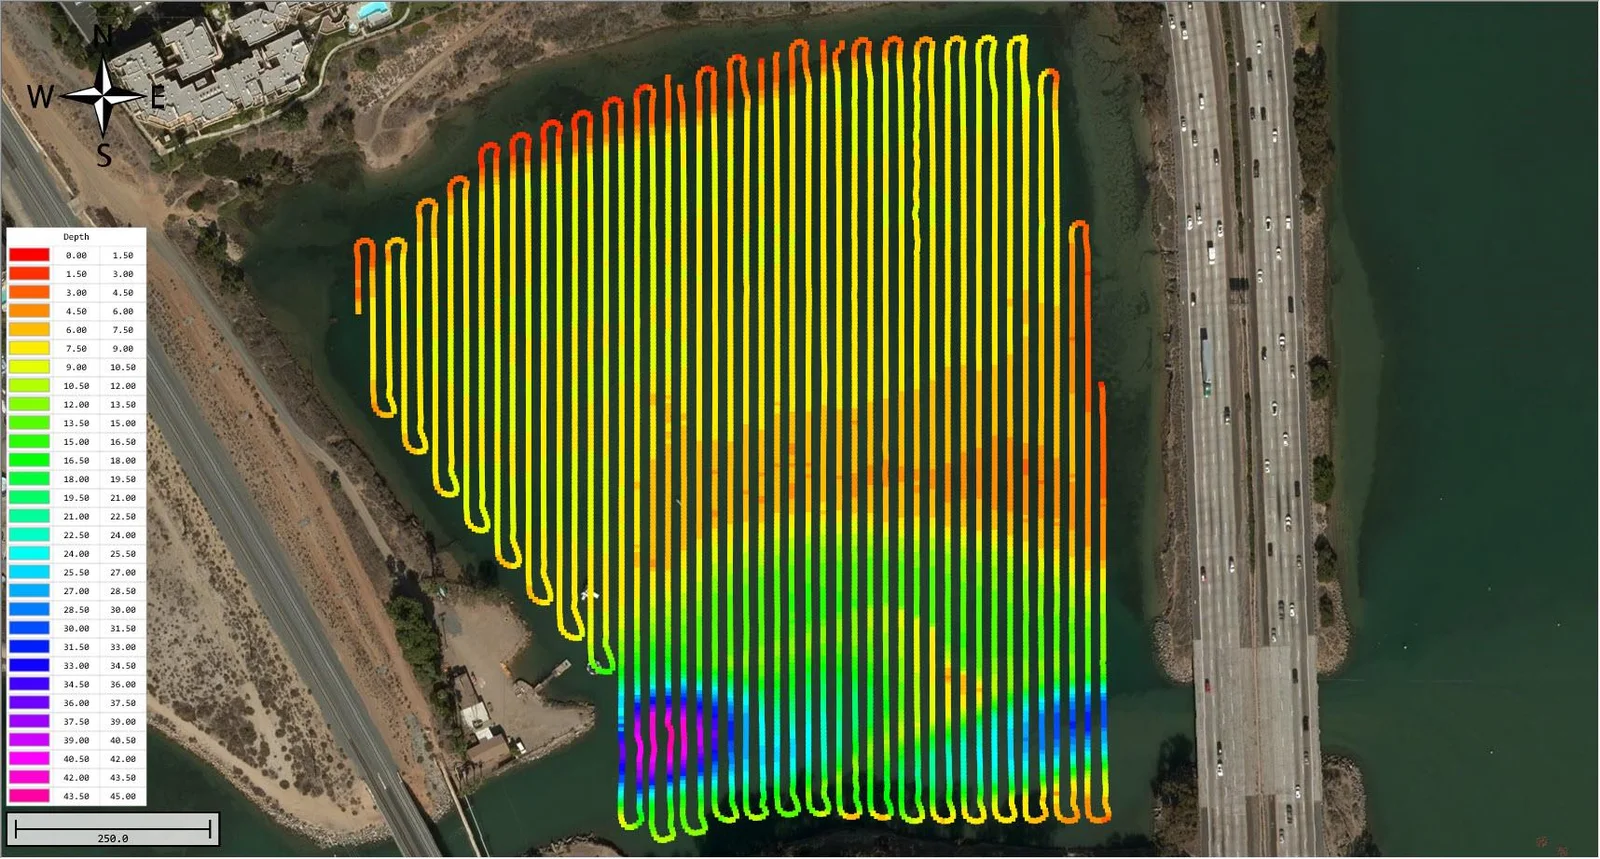
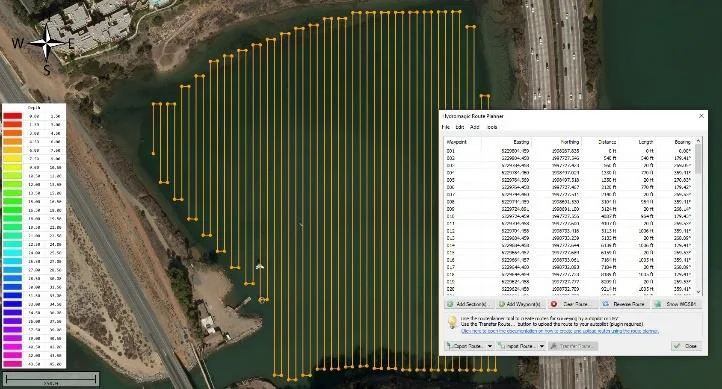
In this coastal lagoon survey, the Hydromagic dataset shows the consistency in data afforded by robotic navigation. The 6 m (20 ft) spaced line plan was followed with extremely low XTE (cross track error), even when tidal currents were present.
Why add an autopilot
Using an unmanned boat such as the CEE-USV™ for hydrographic surveys offers significant safety advantages and potential time and manpower savings versus a manned boat. While this is not always the case, and USVs should be used only for appropriate survey sites, when a USV is suited to the task the benefits can be significant.
After selecting a USV for the survey, the next choice is whether to simply rely on manual operation from the shore or use an autopilot to manage the survey. The CEE-PILOT™ robotic navigation controller blends CEE’s trademark simplified operation with the advanced Dynautics Ltd SPECTRE™ autopilot. This leads to an exceptionally capable navigation package with little added complexity over the manually operated system.
The exceptional line-following ability of the CEE-USV when controlled by the CEE-PILOT system is shown here using survey data from an approx. 300 x 250 m lagoon (1000 x 800 ft), and the benefits in data quality and consistency are clear.
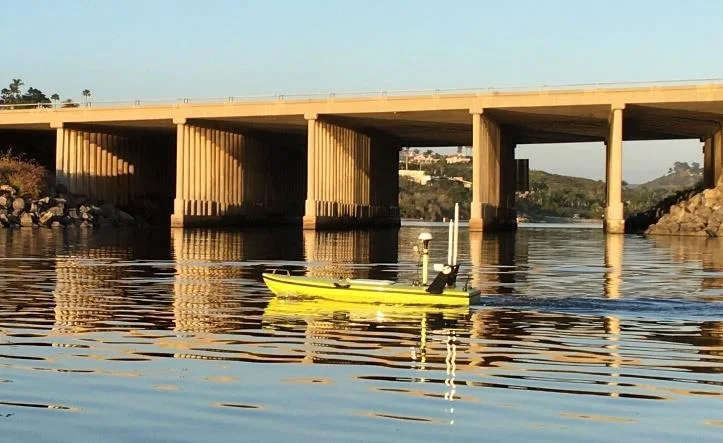
Simple Hydromagic user interface
The CEE-USV offers real time telemetry to a shore PC with over 1000 m (3300 ft) range. There is no requirement for a PC on the vehicle, and the operator can simply drive the boat while looking at the shore display.
With the CEE-PILOT installed, the boat navigation control can be switched from manual to track-following autopilot mode by a single toggle switch on the RC transmitter. As soon as the robotic mode is selected, the USV will head to the first waypoint in its route plan and start surveying.
In order to survey the route, the line plan is first constructed in Eye4Software Hydromagic. This may be done in the field, for example after manually driving the CEE-USV to mark the perimeter. Thus, there is no specific requirement for a pre-defined route plan before starting the job.
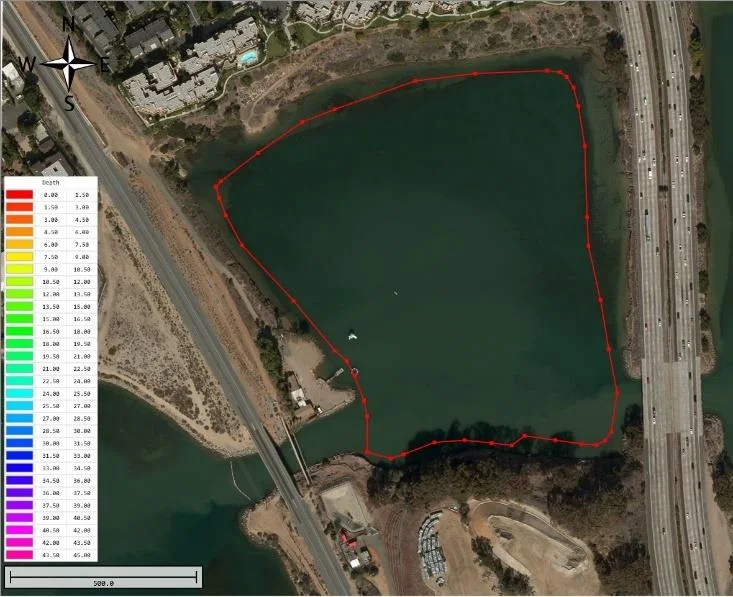
Once the boundary is ready, the route lines are automatically generated with the desired azimuth and spacing. Then all or a subset of the lines may be selected for transfer to the autopilot. The integrated Hydromagic SPECTRE device plugin transfers the route waypoints to the autopilot over the data telemetry link. After a few seconds, the route acceptance is confirmed and the CEE-USV is ready to start surveying when commanded.
Autopilot performance
<15 cm(6 in) typical cross track error on line
6 m(20 ft) line spacing followed
1.4 m(4.5 ft) maximum drift in tidal current
For the lagoon survey, much of the area was calm with light winds and no current. This allowed the USV to follow the 20 ft spaced line plan with remarkable precision. The typical cross track error achieved when on line was under 15 cm (6 in), making it largely impossible to see the track lines behind the sounding data!
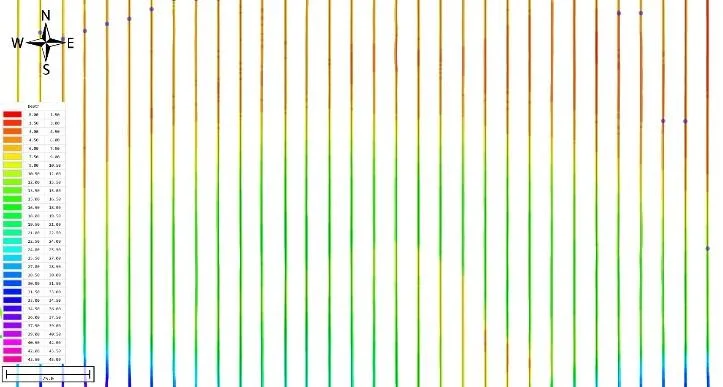
The CEE-USV is a long monohull design with closely spaced propellers, so some drift off the route during turns is unavoidable. However even end of line turns are performed without excessive distance off the survey route.
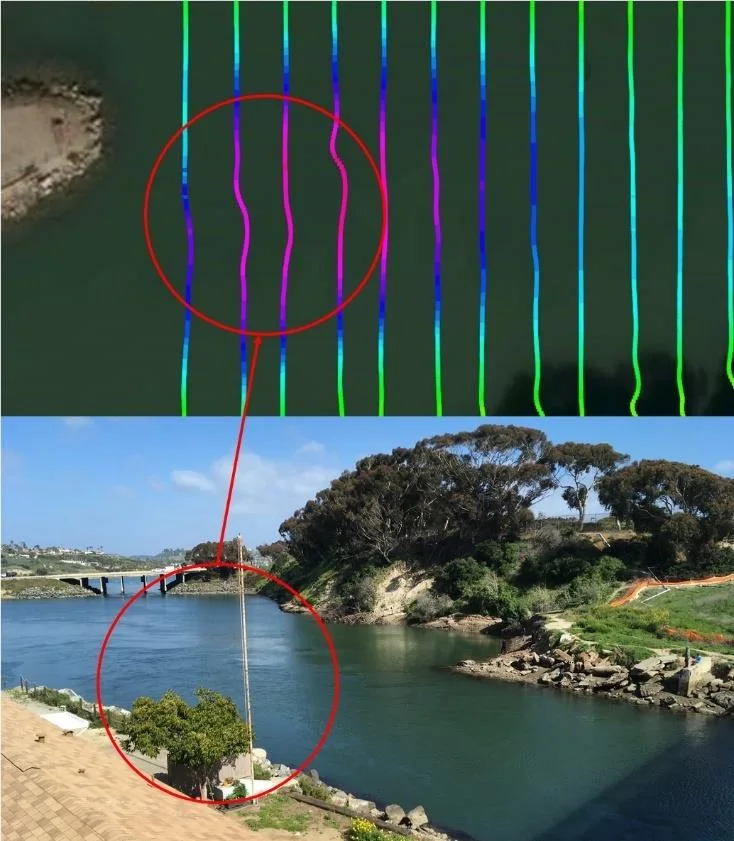
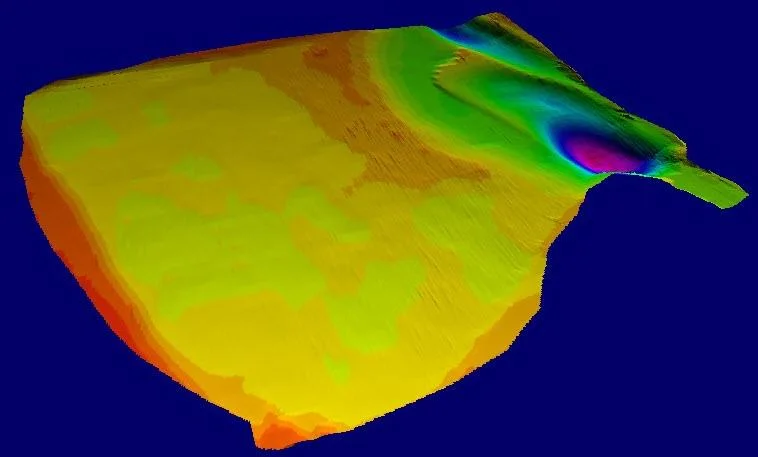
During the lagoon survey, a moderate tidal inflow was present in the southwest corner, evidenced by the deep scour hole. As the CEE-USV transited the current, it immediately started to drift off line but rapidly began correcting the error with a crabbing manoeuvre using increased thrust, rudder deflection, and differential thrust. The maximum drift was still only 1.4 m (4.5 ft).
Vegetation and propeller fouling
When survey areas have surface vegetation such as cattails, eelgrass or seaweed it is less likely that a small USV such as the CEE-USV is the appropriate vehicle to use, owing to the propensity to foul propellers. In this lagoon survey, some eelgrass and debris was present. At one point during the survey, an accumulation of vegetation became large enough to become obvious in the data.
Slight or moderate fouling typically cannot be seen on the track performance but as propellers foul more heavily, the boat does not behave as expected and the autopilot has to work harder to maintain course.
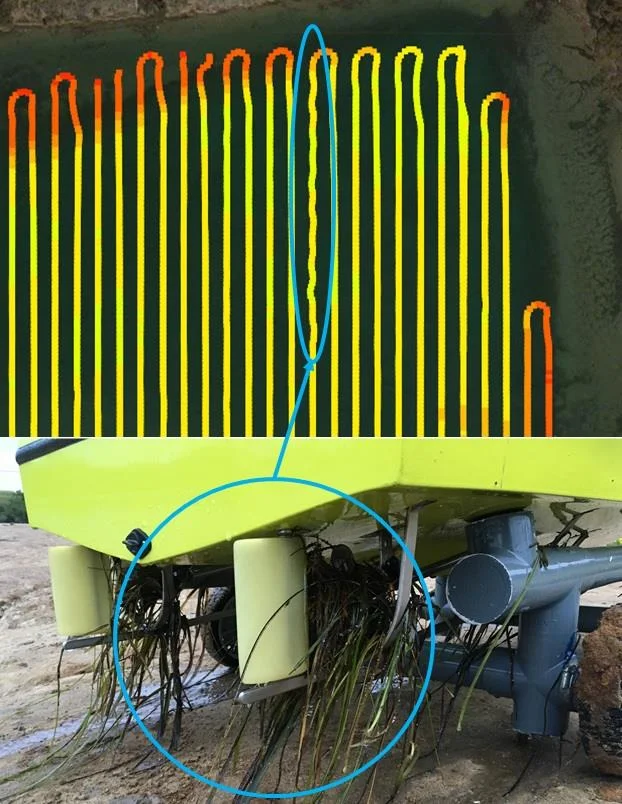
As the CEE-USV may be switched to manual navigation mode at any time, if the operator decides there needs to be a cleaning of the props the boat may be driven back to shore. Any fouling material can be removed and then the boat can be driven back close to the location where the route was interrupted and switched back into autopilot mode to continue as if nothing happened!
Data quality
With the presence of eelgrass in the center of the lagoon, largely in an east-west strip, the ability of the CEE-USV’s on-board CEESCOPE™ echosounder to record a full water column echogram was important to prevent sounding inaccuracies. Spurious signals from debris and vegetation were first eliminated from the sounding data to provide accurate depths across the lagoon.
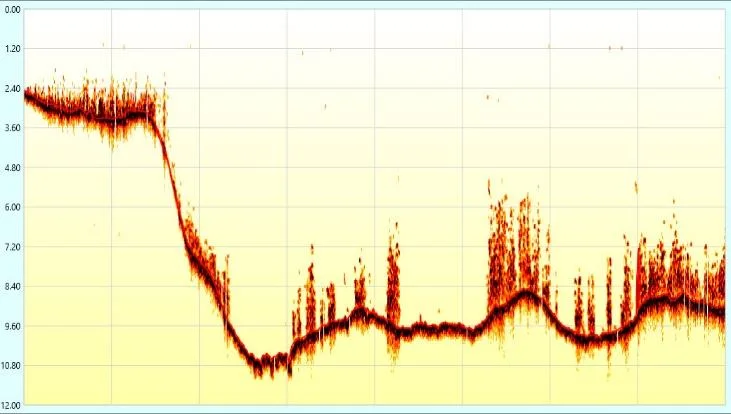
With the equidistant survey lines and consistent coverage, the final bathymetry results are not subject to artifacts from irregular coverage that might otherwise be present, particularly in USV data. This data consistency is obvious in the edited sounding track lines but further demonstrated in a 3D rendering of the TIN modeled XYZ surface. The final product of the survey are accurate and professional looking results for client presentation.
Planning a similar survey?
Tell us about your site and we’ll recommend the right equipment.
Talk to us →
More from the field
6 Jan 2026
Trimble RTX for accurate wastewater sludge comparison surveys with the CEE-USV™
Team Lab monitors sludge in hundreds of wastewater lagoons with the CEE-USV™. Adding a CEESCOPE™ with Trimble CenterPoint® RTX in 2025 gave about 1 in (2.5 cm) vertical accuracy for the lagoon water level on every survey, so repeat surveys compare sludge volumes accurately without anyone going out on the water.
Team Lab monitors sludge in hundreds of wastewater lagoons with the CEE-USV™. Adding a CEESCOPE™ with Trimble CenterPoint® RTX in 2025 gave about 1 in (2.5 cm) vertical accuracy for the lagoon water level on every survey, so repeat surveys compare sludge volumes accurately without anyone going out on the water.
Read case history →
17 Sep 2023
Surveying industrial water with single beam echo sounders and USVs: mine water, frac pits and effluent ponds
How single beam echo sounders and unmanned survey boats are used for industrial water management: reservoir volume, sludge and sediment, and regulatory reporting. Worked examples cover mine tailings storage facilities, frac pits and effluent lagoon dredging.
How single beam echo sounders and unmanned survey boats are used for industrial water management: reservoir volume, sludge and sediment, and regulatory reporting. Worked examples cover mine tailings storage facilities, frac pits and effluent lagoon dredging.
Read case history →
29 Apr 2022
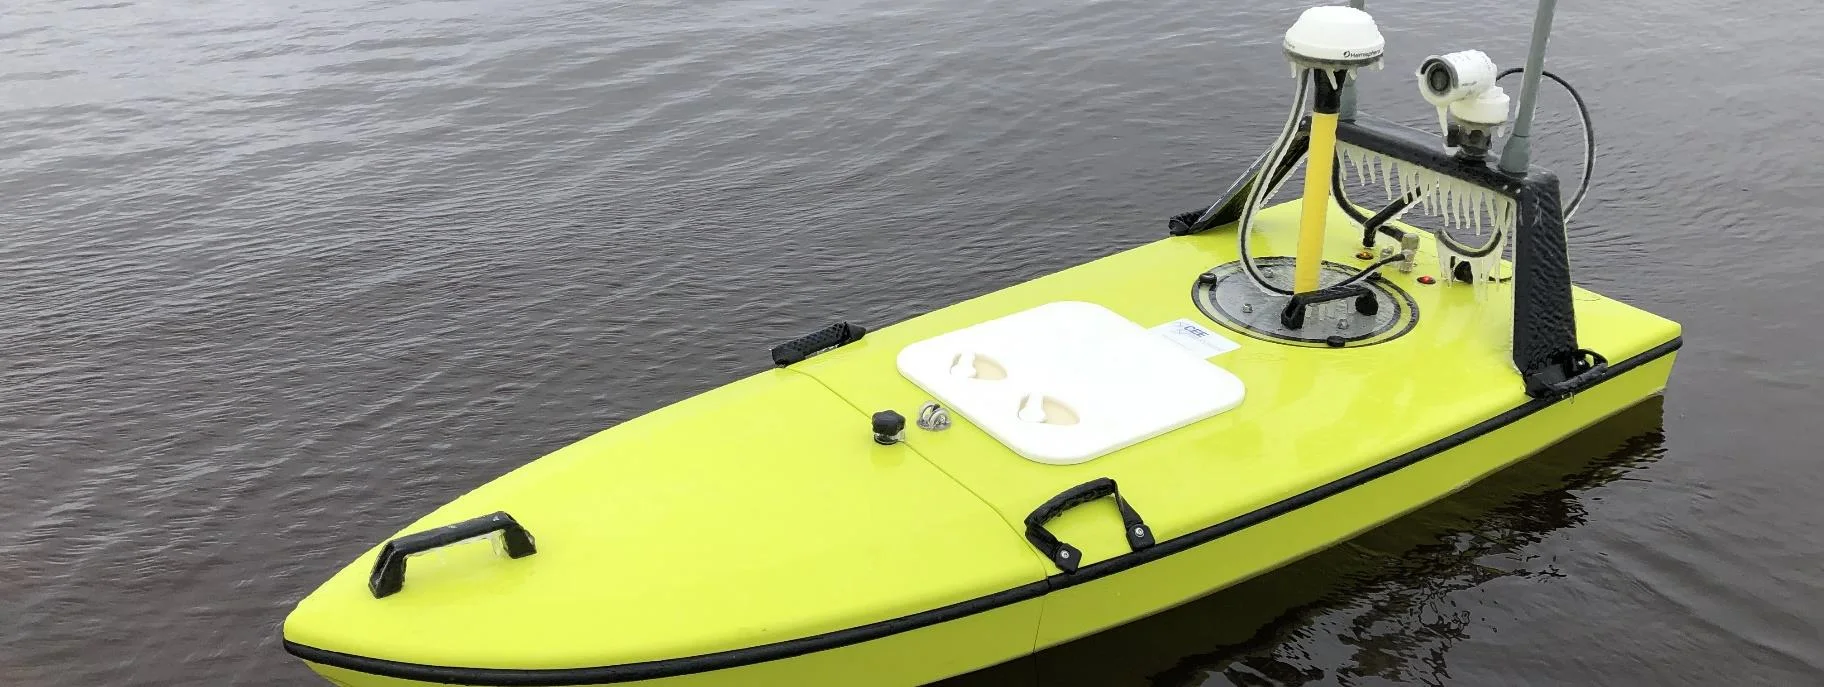
CEE-USV™ surveys a wastewater lagoon in 45 mph winds and sub-zero temperatures
Midwest Planning LLC ran a CEE-USV™ survey of a Minnesota wastewater lagoon in late April, in 45 mph gusts and sub-zero temperatures, with the surveyor operating from a warm truck. Ice on the antennas caused some data drop-outs, but the on-board CEESCOPE LITE™ logged everything, so any gaps could be filled in Hydromagic.
Midwest Planning LLC ran a CEE-USV™ survey of a Minnesota wastewater lagoon in late April, in 45 mph gusts and sub-zero temperatures, with the surveyor operating from a warm truck. Ice on the antennas caused some data drop-outs, but the on-board CEESCOPE LITE™ logged everything, so any gaps could be filled in Hydromagic.
Read case history →